UC Irvine’s Autonomous & Smart Systems Guard (AS²Guard) research group, led by Alfred Chen, studies the security of AI in the latest small-UAS autonomy functions. Its FlyTrap study of autonomous target tracking was presented at NDSS 2026, responsibly disclosed to the affected drone makers, and covered by more than 15 news outlets; its MirageMarker study of marker-based autonomous landing appears at IROS 2026. With GWU and TSU, the group is developing defenses for vision-language-model-enabled drones and a drone-delivery benchmark.

Research thrusts

  1. 01

    FlyTrap

    The first security analysis of camera-based autonomous target tracking in drones, demonstrated against commercial systems and presented at NDSS 2026.

    UC-01

  2. 02

    MirageMarker

    The first security study of fiducial-marker pose estimation for precision landing, evaluated against the PX4 autopilot’s native landing mode in NVIDIA Isaac Sim (IROS 2026).

    UC-01

  3. 03

    Securing vision-language autonomy

    Ongoing work on defending vision-language models used for drone tracking and landing against visual prompt injection.

    UC-01with GWU

Figures

From the research

Simulated drone above a fiducial marker board with an inset downward camera view.
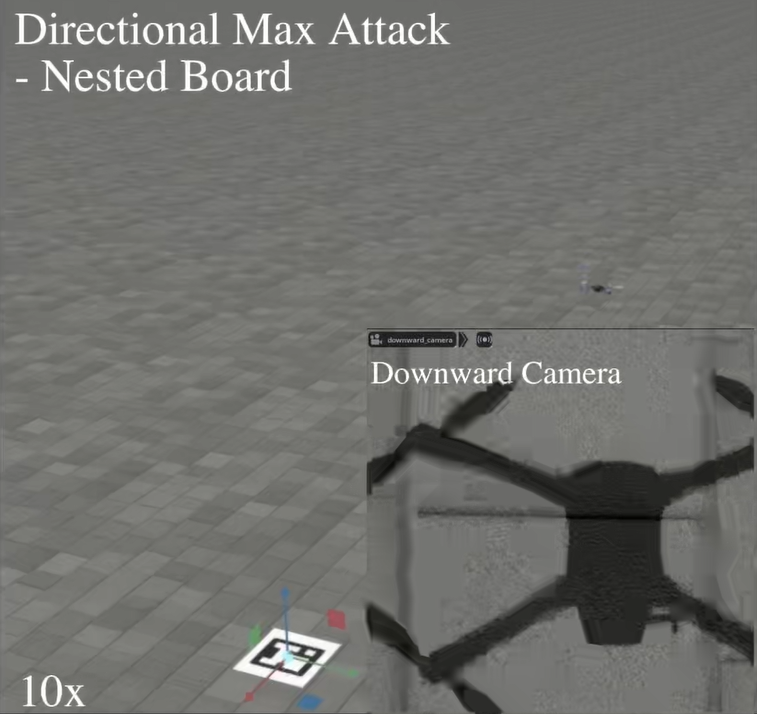
UC IrvineA second MirageMarker attack objective in simulation, inducing a large directional pose error during landing.
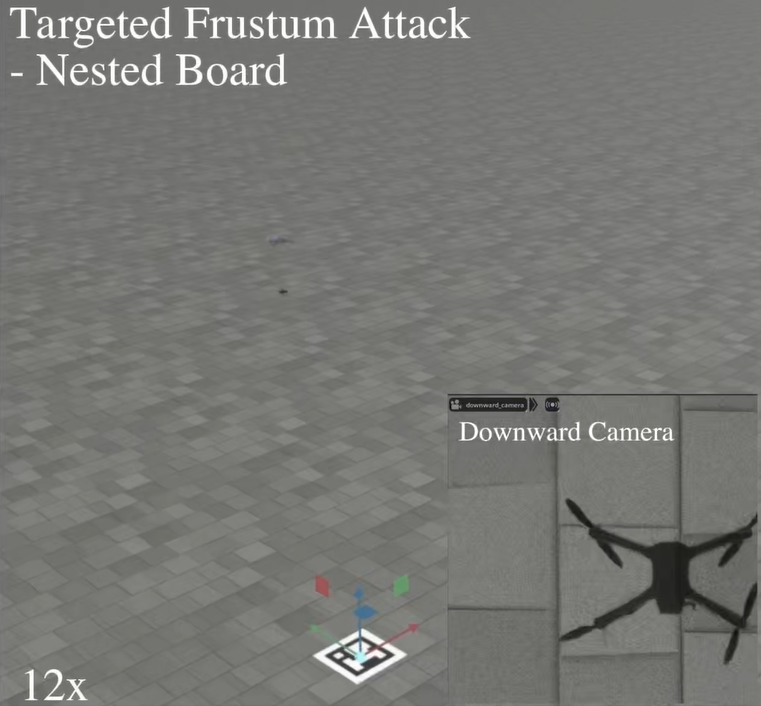
Simulated drone landing on a paved area with an inset downward camera view of a fiducial marker board.
UC IrvineMirageMarker evaluated in NVIDIA Isaac Sim against the PX4 autopilot’s native precision-landing mode. Subtle geometric changes to the marker board shift the touchdown point far from the pad.

Demos

See UC Irvine's work in action

All demos

UC IrvineUC-01Real world

FlyTrap: attacking autonomous target tracking

UC Irvine’s demonstration of FlyTrap, the first security analysis of camera-based autonomous target tracking in drones. A specially patterned umbrella draws a tracking drone dangerously close. Evaluated on commercial drones and presented at NDSS 2026.

UC IrvineUC-01Real world

MirageMarker on real hardware

A real-world capture of marker-based pose estimation, comparing the estimate from a clean marker with one under the MirageMarker perturbation.

UC IrvineUC-01Simulation

MirageMarker: misleading precision landing in simulation

Subtle geometric changes to a fiducial landing-marker board shift a PX4 drone’s precision landing 8–12 m off the pad in NVIDIA Isaac Sim, while clean boards land within centimeters. Presented at IROS 2026.

People

Researchers and students

PhD students1

  • Junchi Lu

Publications

Publications

2 published or accepted papers

  1. FlyTrap: Physical Distance-Pulling Attack Towards Camera-based Autonomous Target Tracking Systems

    S. Xie, M. Fakih, J. Lu, F. Alshammari, N. Wang, T. Sato, H. Bouzidi, M. Al Faruque, Q. A. Chen

    Network and Distributed System Security Symposium (NDSS), 2026

    ConferenceUC IrvineUC-01

  2. MirageMarker: A Black-Box Pose Estimation Attack for Autonomous UAV Landing

    J. Lu, F. Alshammari, S. Xie, X. Liang, Q. A. Chen

    IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026

    ConferenceUC IrvineUC-01